Fieldbus Protocol
-
CANopen Mini Bootloader PAULUS0,00 €
ANSI-C source code of an CANopen boot loader useful for easy In-System-Programming and firmware updates (not only for CANopen devices)
Modern device designs need enormous flexibility in hard- and software. Today hardware is equipped with plenty of resources in order to allow software changes later on. Software itself has to provide means to enable an update/upgrade of the current firmware. At this point in-system-programming offers the greatest possibilities, and thus a change of the software too.
Bootloader with a communication interface allow to do firmware updates by using an appropriate network.
Standardized communication objects and algorithms garuantee a high level of transparency and user friendliness. -
m4d - The CANopen Gateway Server0,00 €
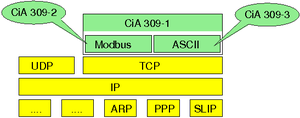
The CANopen Gateway Server m4d is an universal CANopen Master application. It features a simple CANopen oriented command language according to CiA 309-3. The CANopen commands are accessible directly or over a TCP/IP socket interface.
The subject Ethernet access down to the fieldbus layer is intensely discussed. The CANopen Gateway Server provides the solution of Ethernet access down to the fieldbus layer right now and relies on the current and field proven CANopen technology.
-
Linux CAN can4linux / CANopen Driver0,00 €
The universal LINUX CAN device driver can4linux supports a broad range of CAN interfaces. ports AT-CAN-MINI is supported as well as a a bunch of interfaces from other manufacturers. Source code of the software is available. It compiles for Kernels 2.0, 2.2 2.4 and latest 2.6.
An derived version for embedded Linux-devices using micro controllers with integrated CAN or with external stand alone CAN controllers is available too. This one is configured at compile time for a specific hardware architecture.
can4linux is an universal LINUX™ device driver. It can be used to control ISA or PCI interface boards with CAN interface, or embedded CAN controller solutions. The GPLed sources are currently supporting CAN controllers (Philips SJA1000, Intel 82527, Infineon SAK82C900 and Motorola FlexCAN, TwinCAN). The driver can be compiled for all LINUX™ kernel versions 2.4 to 2.6. (older version for kernel versions 2.0 to 2.2 are available.)
-
Device Driver für VxWorks0,00 €
The universal VxWorks CAN device driver can4vxworks supports a broad range of CAN interfaces.
The can4vxworks driver is a universal VxWorks device driver and is used for controlling of ISA-, PCI- and PC104 interface cards with CAN bus interface. It supports the CAN controller Philips SJA1000 and the sources can easily be adapted to use any other CAN controller .
-
J1939 Protocol Stack0,00 €
With the J1939 server of port it is possible to get access to SAE J1939 network, maybe for diagnosis purposes. Therefore the provides a TCP/IP interface, which the connected client uses to exchange messages with other ECUs in the network. Instead the TCP/IP interface, the usage of the command line is possible too.
The demo version of J1939server for can4linux is available.
The J1939 Protocol Stack (in ANSI-C) is a complete implementation of the SAE J1939 protocol. By providing all communication mechanisms defined in the SAE J1939 specification the stack allows the developer to focus solely on the implementation of the application.
An adaption to other target systems can be performed easily within a few days due to the modular structure of the J1939 Protocol Stack based on the OSI layer model.
-
acontis - EC-Master - EtherCAT Master Stack0,00 €
The EC-Master Stack is designed and optimized to run on different embedded (real time) operating systems.
Already existing implementations are available Linux (with and without Real-Time), Microsoft Windows® 10/11, Wind River VxWorks, BlackBerry QNX, IntervalZero RTX64, TenAsys INtime®, Integrity, Xenomai, On Time RTOS-32, RTEMS, FreeRTOS, eCos, TI-RTOS, T-Kernel and more operating systems.
The EtherCAT MainDevice stack, formerly Master, can be ported on any other embedded operating systems. -
PROFINET Protocol Stack (CC-A / CC-B RT1)0,00 €
CC-Link IE TSN builds on the benefits of CC-Link IE by improving communication functions and synchronization accuracy. The demand for TSN support will therefore continue to increase as this technology enables different networks to be combined on the same main line and to provide real-time communication through time synchronization.
-
EtherCAT Protocol Stack0,00 €
The EtherCAT Protocol Stack provides all required services for a compliant communication according to the EtherCAT Standard IEC61158. . It facilitates easy and fast development of EtherCAT Slave devices. The functional range can be extended by additional modules. Access to the hardware is carried out via a hardware abstraction layer. These drivers are available for selected hardware.